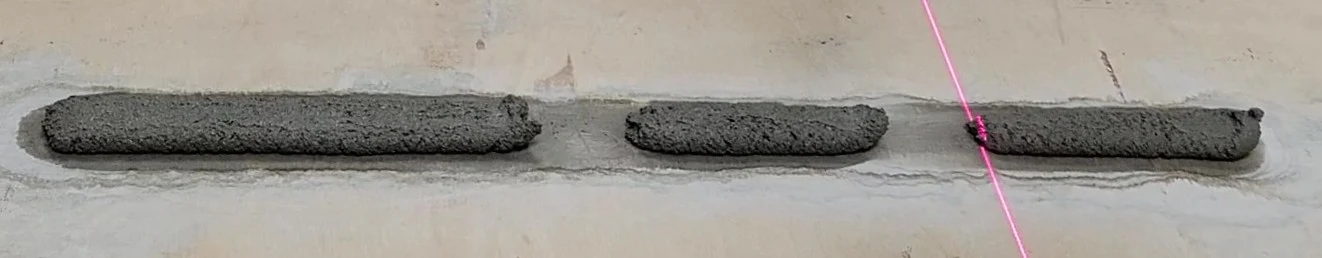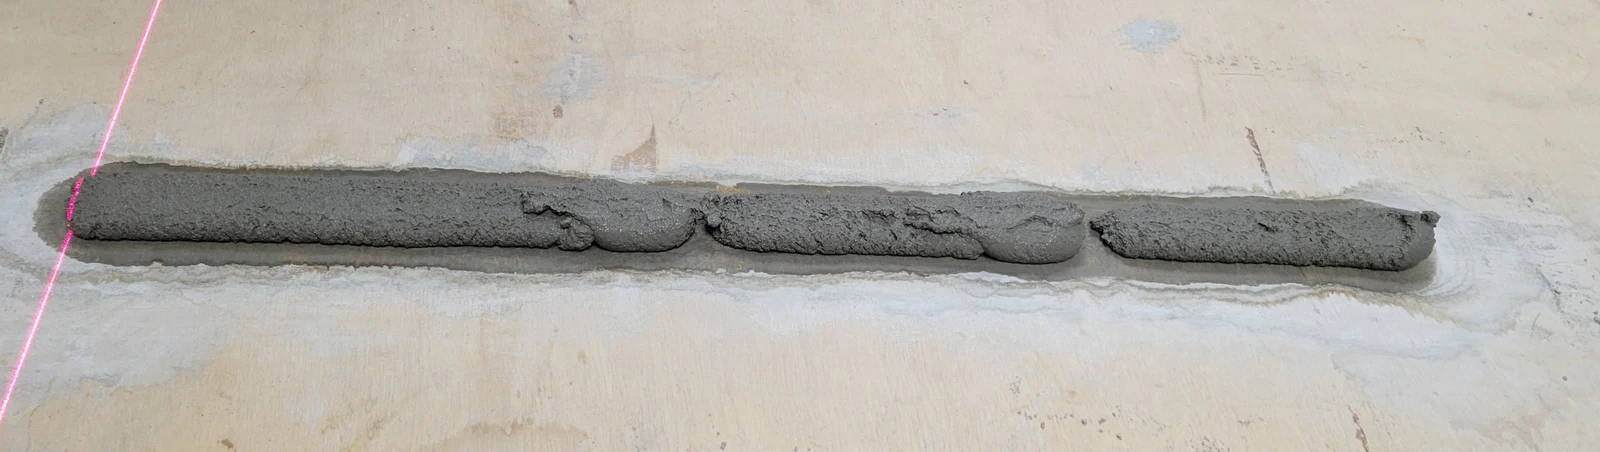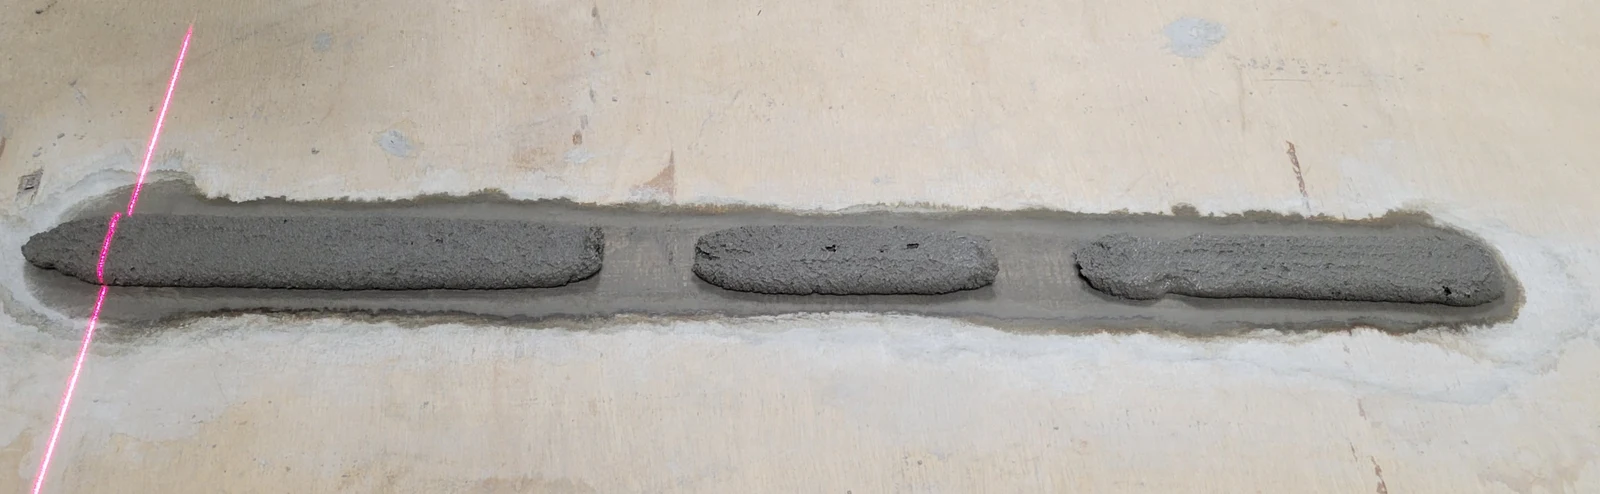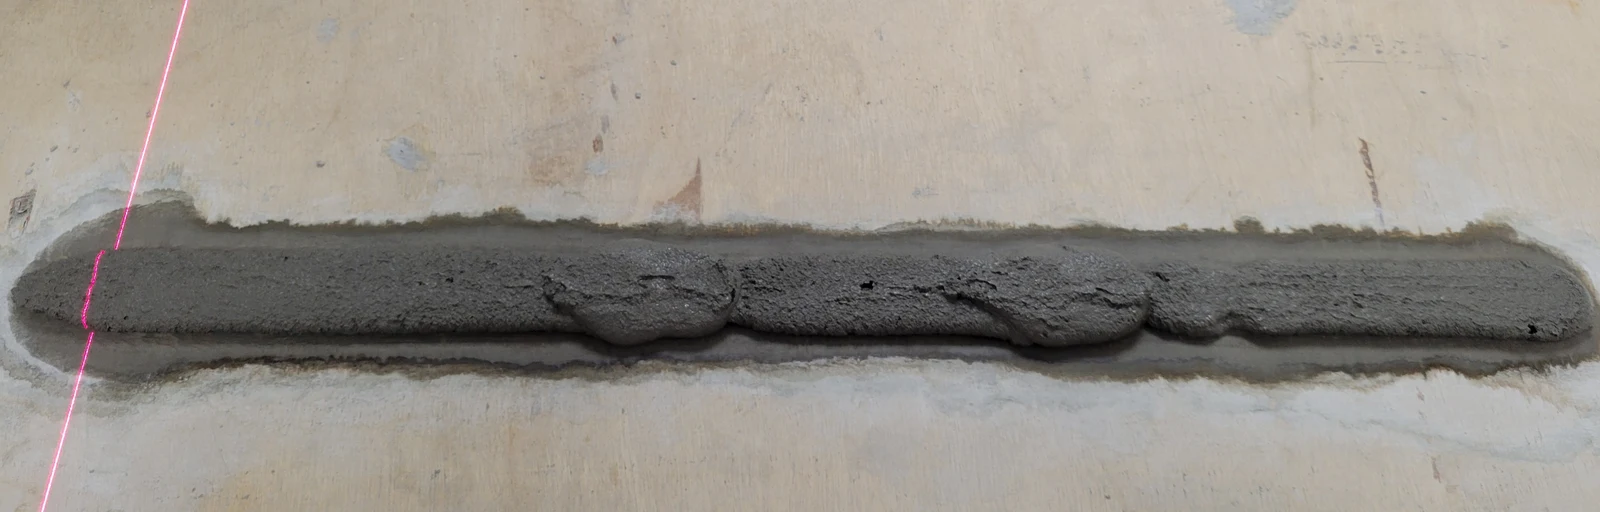
From measured gaps to localized repair
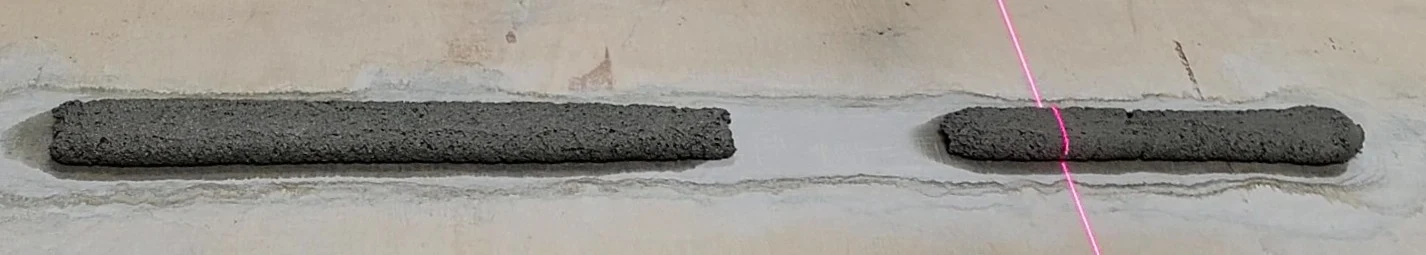
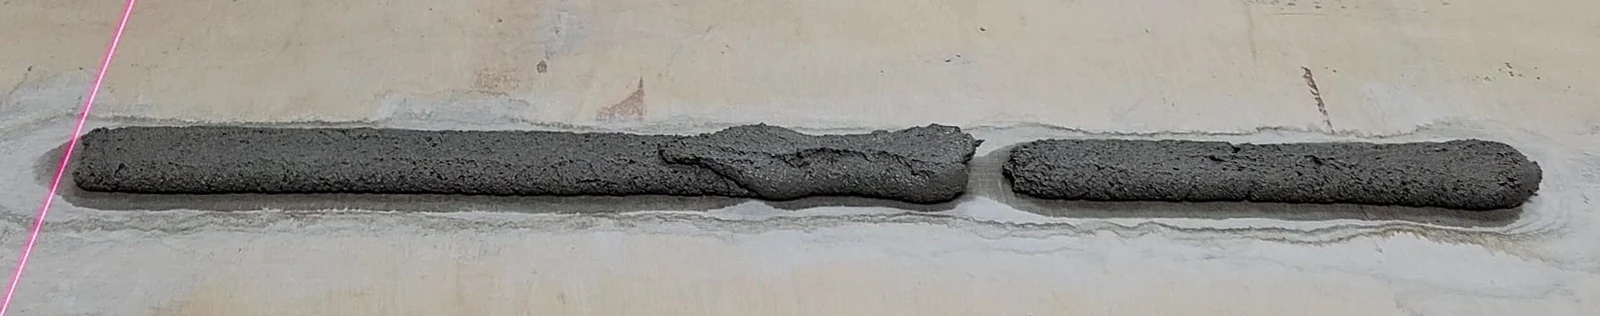
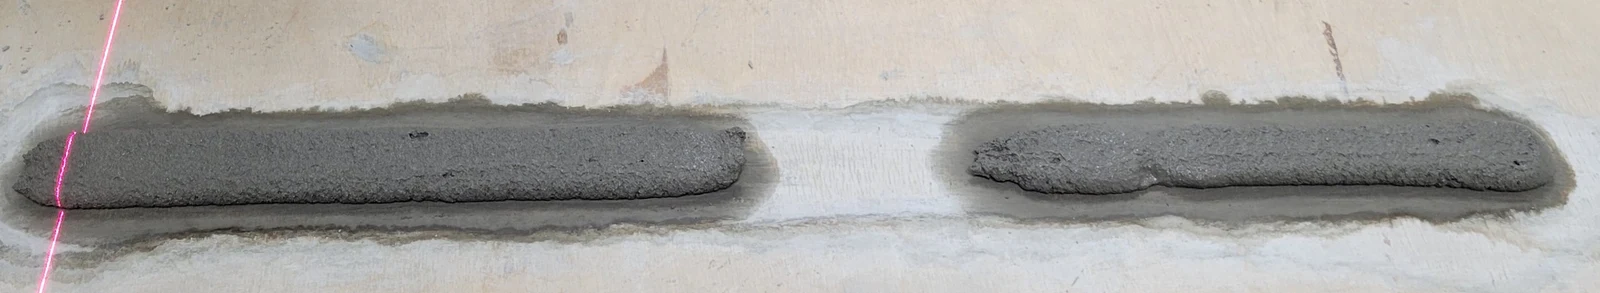
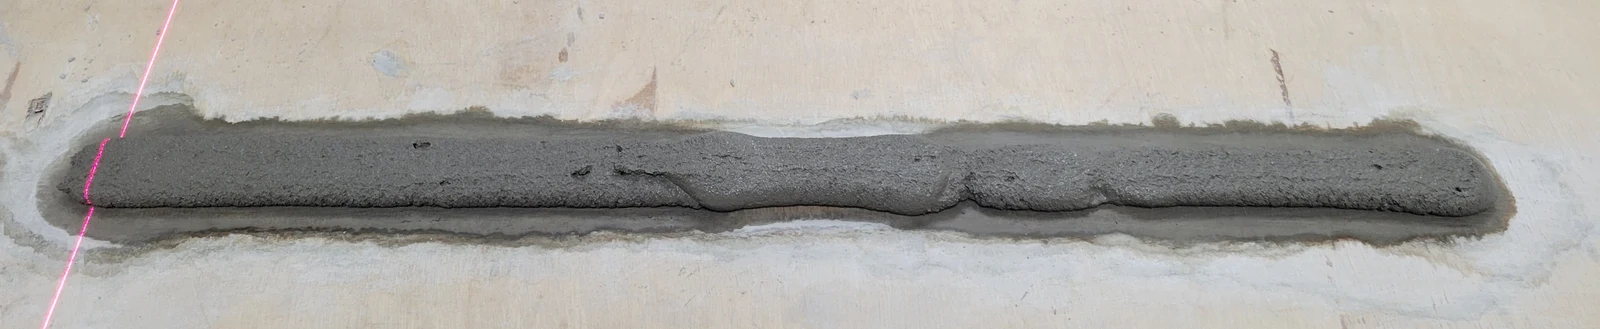
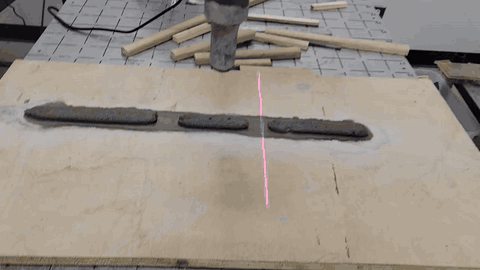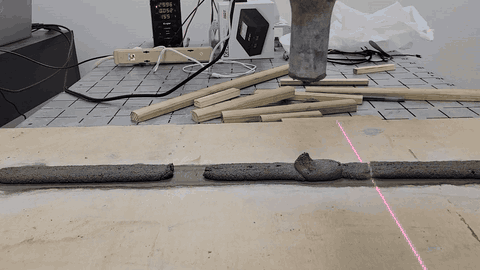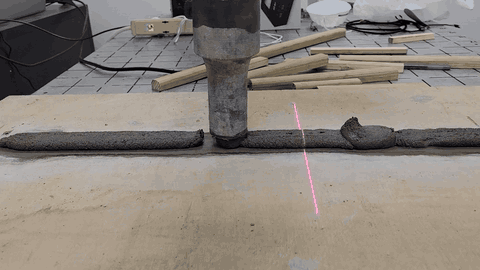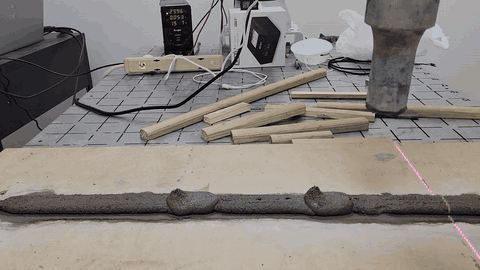
Material interruptions during robotic construction 3D printing can leave gaps in an already deposited layer. This research localizes those material-loss regions from measured geometry, returns the robot to the affected locations, and deposits material within the same layer. Post-repair laser measurements verify the geometric response.
Sensing and repair planning
Laser profiles describe deposited geometry and distinguish genuine material-loss regions from invalid scanner observations. The measured gaps define where localized repair is needed. The RGB camera documents the experiments; geometric feedback comes from the laser scanner.
Grey-Box Repair uses a semi-empirical deposition model and constrained inverse command selection to relate material delivery, robot travel, and material age to the requested deposition.
Grey-Box + Residual-Informed Repair adds an offline-trained spatial ridge-residual correction to guide the deposition request. Its coefficients remain frozen during execution. This strategy was implemented and evaluated in physical single-gap and double-gap repairs; it does not use reinforcement learning.
The physical evaluation includes single- and double-gap repair. Repair does not imply complete gap filling or elimination of overfill. Experimental conditions differ, so observed improvements cannot be attributed solely to residual learning.
Research workflow
- Robotic material deposition — Deposit the mortar layer.
- Laser-based geometric measurement — Measure the deposited geometry.
- Material-loss gap localization — Identify the regions requiring repair.
- Grey-box and residual-informed repair planning — Select feasible, spatially targeted repair commands.
- Same-layer repair execution and geometric verification — Repair the measured gaps and re-scan the layer.
Manuscript Under Review
Sensor-Guided Same-Layer Repair of Material-Loss Gaps in Robotic Construction 3D Printing
Muhammad Arslan, Abdul Wahid Mangi, Vedhus Hoskere.
Automation in Construction · Elsevier.